Prof. Jiyeon Kang

GIST

AI학과 / AX학과

로봇트랙

2026

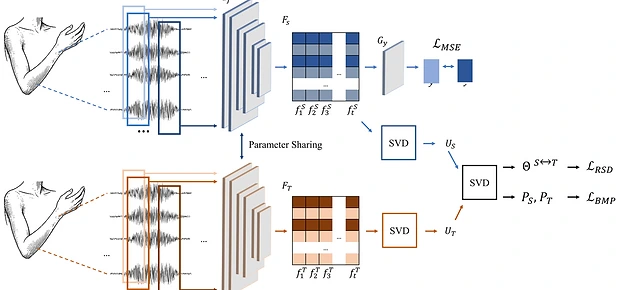
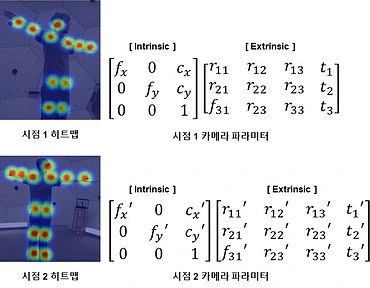
Re-entangling subject-dependent sEMG variation for label-free wrist kinematics estimation

Kihyun Kim and Jiyeon Kang

Under revision

2026
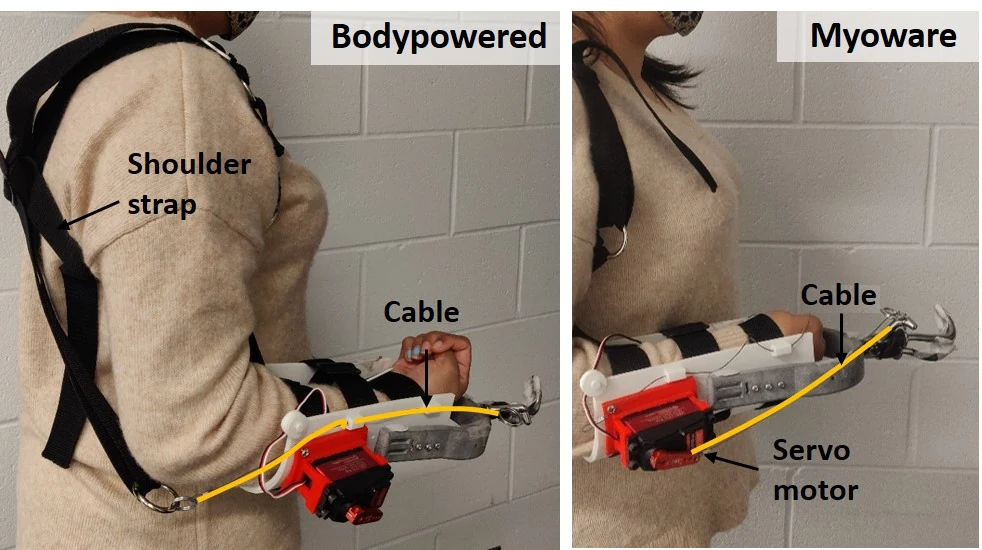
Body-powered and myoelectric prostheses using a plug-and-play module

A feasibility study comparing body-powered and myoelectric prostheses using plug-and-play module

Rishi Adusumilli, Souvik Poddar, Mohamed Sulaiman, and Jiyeon Kang

IEEE Access 14 (2026) 160801–160812.

2026
image.png

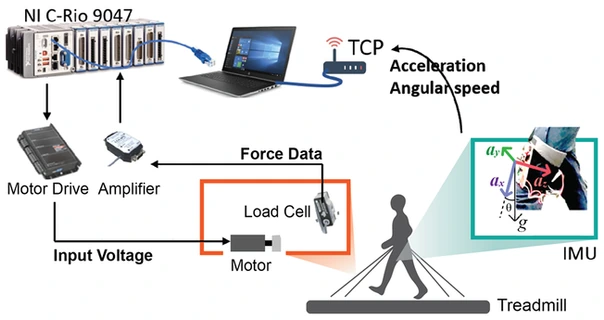
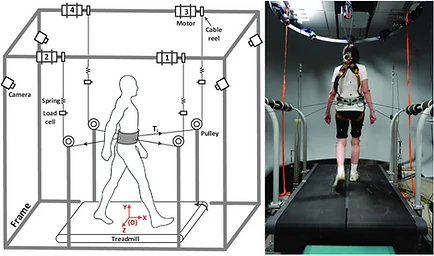
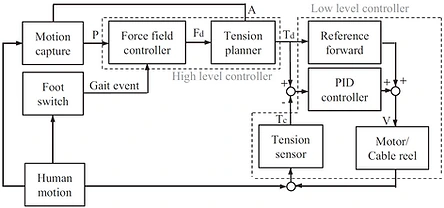
Enhanced feedforward force controller for cyclic disturbance compensation in a gait-training robot

Jin-Woo Lee*, Sahil Kapahi*, Souvik Poddar, and Jiyeon Kang  

IEEE Trans. Med. Robot. Bionics (2026).

2026
image.png

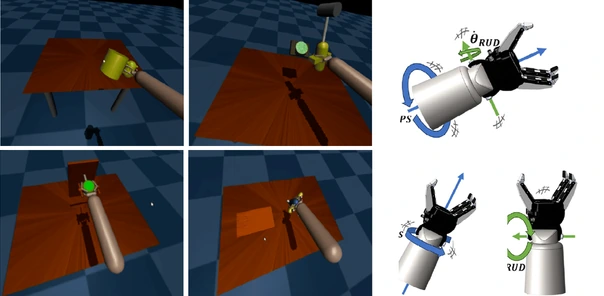
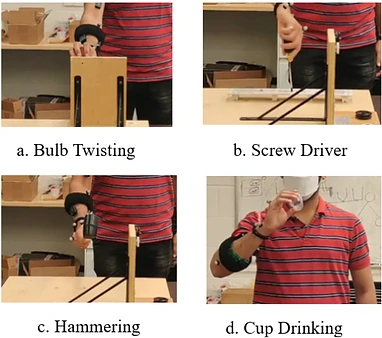
User-centred design of multi-DoF prosthetic wrist controllers: performance and preference in daily living tasks

Deepti Bharadwaj, Ingyun Ahn, Saurabh S. Deshmukh, and Jiyeon Kang
Healthc. Technol. Lett., 13 (2026) e70092.

2026
image.png

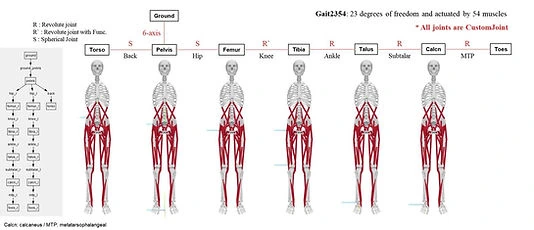
Joint torque estimation from daily living motion for passive sarcopenia monitoring in older adults

Jaebeom Jo, Kihyun Kim, Min-gu Kang, Kanghyun Ryu, Junhyoung Ha, and Jiyeon Kang

J. NeuroEng. Rehabil. 23 (2026) 161.

2026
image.png

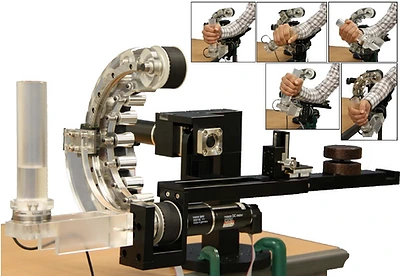
A robotic emulator for user-driven design of multi-DOF transradial prostheses

Souvik Poddar, Eleonora Botta, Deanna Gates, and Jiyeon Kang  
IEEE Robot. Autom. Lett. 11 (2026) 4689–4696.

2026
image.png

Improving foot rocker via robot-resisted gait training with self-awareness biofeedback in adults with cerebral palsy

Souvik Poddar, Jaehyeong Park, Eleonora M. Botta, Lora Cavuoto, Jeanne Langan, and Jiyeon Kang

IEEE Trans. Neural Syst. Rehabil. Eng. 34 (2026) 46–56.

2026

Design and evaluation of Pilates-Bot: a cable-driven rehabilitation robot for bedridden patients

Seonghun Jeong, Ingyun Ahn, and Jiyeon Kang

International Conference on Control, Automation and Systems (ICCAS), 2026.
2026

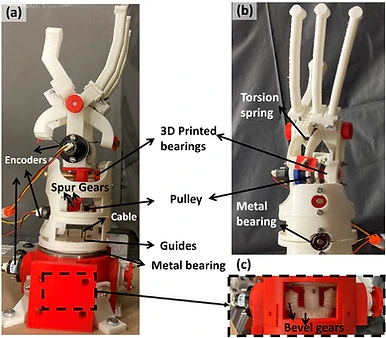
Cable-driven transradial robotic prosthesis with fully actuated wrist using parallel mechanism

Ingyun Ahn and Jiyeon Kang

International Conference on Control, Automation and Systems (ICCAS), 2026.

2026

Wave-disturbance response of a hybrid feedback station-keeping system incorporating force sensing for an unmanned surface vehicle

Gyeong-ho Kim, Seoyeon Kim, Jiyeon Kang, Seok Chung, and Seong Jin Kim

International Conference on Control, Automation and Systems (ICCAS), 2026.

2026

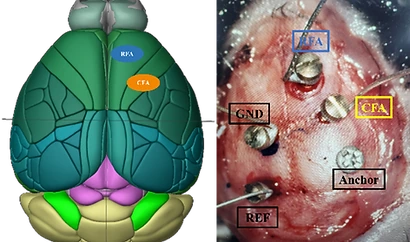
Exercise-induced mitigation of cortical slowing and stabilization of beta-burst dynamics in a Parkinson’s disease mouse model

Jinwoo Ahn, Daeun Roh, Daeyeon Kim, Doeun Kim, Yunjong Lee, Euiheon Chung, and Jiyeon Kang
Annual International Conference of the IEEE Engineering in Medicine and Biology Society (EMBC), 2026.

2026
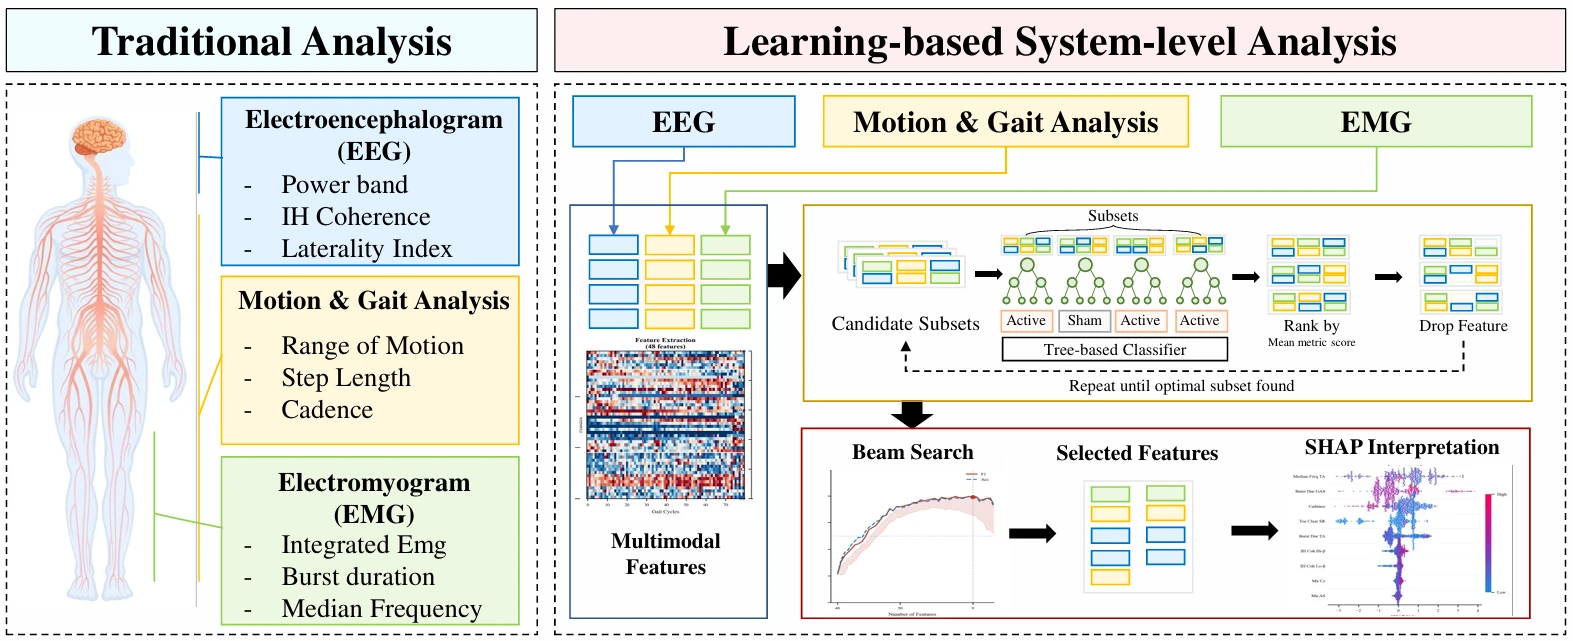
Multimodal EEG, gait, and EMG analysis of tDCS-induced gait adaptation

An exploratory multimodal characterization of tDCS-induced gait adaptation in Parkinson’s disease

Youngkee Kim, Heegyu Kim, Yousong Shin, Kyungmin Kwon, Hyo Jin Park, Sung Chan Jun, Seong-Min Choi, and Jiyeon Kang
IEEE International Conference on Systems, Man, and Cybernetics (SMC), 2026.

2026
Cable-driven bedside training robot with assist–resist-as-needed control

Assist–resist-as-needed robotic control for cable-driven bedside training

Jin-Woo Lee, Seonghun Jeong, and Jiyeon Kang
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026, pp. 12360–12367.

2025
화면 캡처 2025-12-02 203511.png

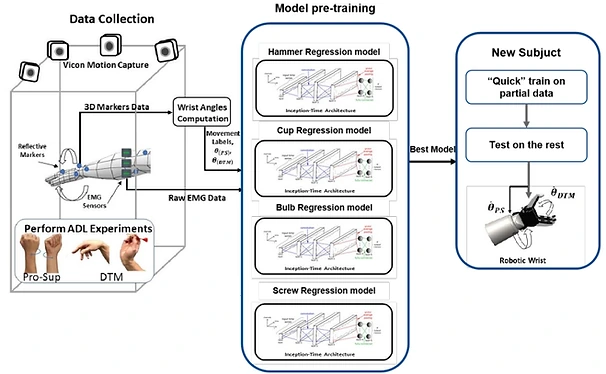
Subject-independent sEMG-based prosthetic control using MAMBA2 with domain adaptation

Kihyun Kim and Jiyeon Kang  
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025, pp. 16673–16679.

2025
그림1.png

The effects of treadmill exercise on brain signals in Parkinson’s disease animal models

Jinwoo Ahn, Daeum Roh, Yunjong Lee, Euiheon Chung, and Jiyeon Kang  
Brain Engineering Society of Korea (BESK), 2025.

2025

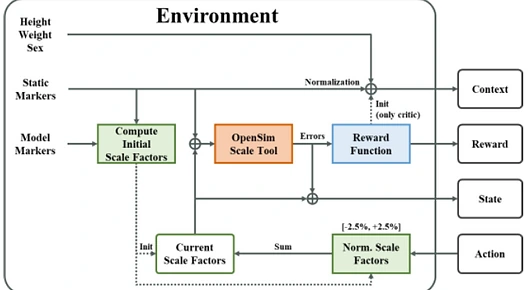
Reinforcement-learning-driven automatic scaling in OpenSim for enhanced human motion analysis

Jaebeom Jo and Jiyeon Kang

Institute of Control, Robotics and Systems (ICROS), (2025) 620–621.

2024
스크린샷 2024-04-18 090730.png

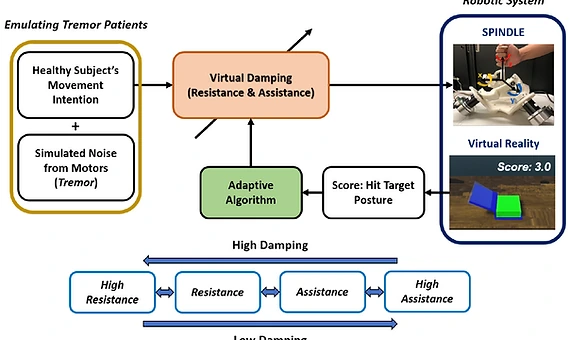
Resist-as-needed ADL training with SPINDLE for patients with tremor

Nikhil T. Kantu, Ryan Osswald, Amit Kandel, and Jiyeon Kang

IEEE Trans. Neural Syst. Rehabil. Eng. 32 (2024) 1735–1748.

2024

Development of a framework for estimating sarcopenia using vision-based pose estimation techniques and deep learning models for motion analysis

Kihyun Kim, Jaebeom Jo, and Jiyeon Kang

Institute of Control, Robotics and Systems (ICROS), (2024) 752–753.

2024

Prediction of ground reaction forces and joint torque through squatting motion with deep learning algorithm

Jaebeom Jo, Junhyoung Ha, and Jiyeon Kang

Institute of Control, Robotics and Systems (ICROS), (2024) 123–124.

2024

Adaptive resistance in robotic rehabilitation for enhanced upper limb function in stroke patients

Euiseo Yoon, Joon-Ho Shin, and Jiyeon Kang

Institute of Control, Robotics and Systems (ICROS), (2024) 927–928.

2023
zixia.png

Continuous joint velocity estimation using CNN-based deep learning for multi-DoF prosthetic wrist for activities of daily living

Zixia Meng and Jiyeon Kang

Front. Neurorobot., 17 (2023) 1185052

2023
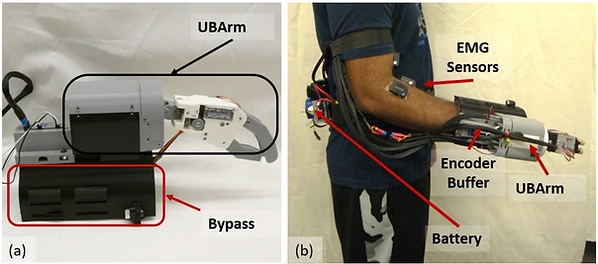
ubarm.png

A transradial prosthesis with a high-functional wrist for various daily living task

Michael Kim and Jiyeon Kang

International Conference on Ubiquitous Robots (UR), 2023, 127–132

2022
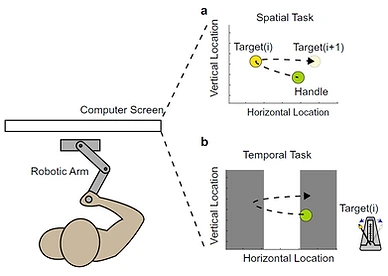
화면 캡처 2023-02-20 212333.png

Temporal and spatial goal-directed reaching in upper limb prosthesis users

Christina Lee, Michael A. Gonzalez, Jiyeon Kang, and Deanna H. Gates

Exp. Brain Res. 204 (2022) 3011–3021

2022
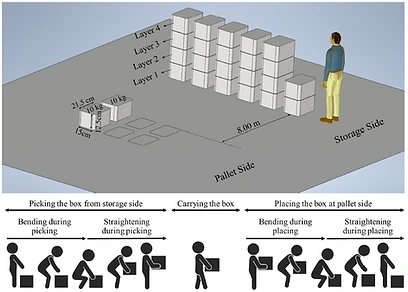
화면 캡처 2022-09-02 135019.png

Adjustments in shoulder and back kinematics in repetitive palletizing task

Saeb R. Lamooki, Lora A. Cavuoto, and Jiyeon Kang

Sensors, 22 (2022) 5655

2022
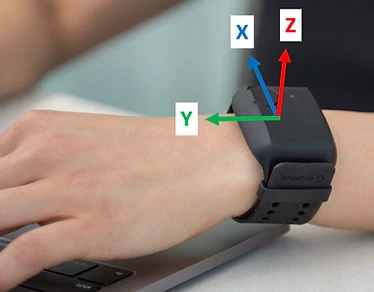
화면 캡처 2022-09-02 135759.png

A data analytic end-to-end framework for the automated quantification of ergonomics risk factors across multiple tasks using a single wearable sensor

Saeb R. Lamooki, Sahand Hajifar, Jiyeon Kang, Hongyue Sun, Fadel M. Megahed, and Lora A Cavuoto

Appl. Ergon. 102 (2022) 103732

2022
화면 캡처 2022-09-02 132450.png

A lightweight transradial prosthetic emulator for optimizing prosthetic wrist design

Souvik Poddar and Jiyeon Kang

IEEE Ras & Embs International Conference on Biomedical Robotics and Biomechatronics (BioRoB), 2022.

2022
fazil.png

CNN-based controller for multi-DoF prosthetic wrist using sEMG data during activities of daily living

Mohamed Fazil, Zixia Meng, and Jiyeon Kang

IEEE Ras & Embs International Conference on Biomedical Robotics and Biomechatronics (BioRoB), 2022.

2021
화면 캡처 2022-09-02 143733.png

Getting a grip on the impact of incidental feedback from body-powered and myoelectric prostheses

Michael Gonzalez, Christina Lee, Jiyeon Kang, R. Brent Gillespie, and Deanna H. Gates

IEEE Trans. Neural Syst. Rehabil. Eng. 29 (2021) 1905 - 1912

2021
화면 캡처 2022-09-02 144151.png

Acute effects of a perturbation-based balance training on cognitive performance in healthy older adults: a pilot study

Dario Martelli, Jiyeon Kang, Federica Aprigliano, Ursula M. Staudinger, and Sunil K. Agrawal

Front. Sports Act. Living 3 (2021) 688519

2021
화면 캡처 2022-09-02 144511.png

A novel framework for designing a multi-DoF prosthetic wrist control using machine learning

Chinmay P. Swami, Nicholas Lenhard, and Jiyeon Kang

Sci. Rep. 11 (2021) 15050

2021
화면 캡처 2022-09-03 060926.png

Personalized and nonparametric framework for detecting changes in gait cycles

Saeb R. Lamooki, Jiyeon Kang, Lora A. Cavuoto, Fadel M. Megahed, and L. Allison Jones-Farmer

IEEE Sens. J. 21 (2021) 19236–19246

2021
화면 캡처 2022-09-03 061737.png

A novel 3-RRR spherical parallel instrument for daily living emulation (SPINDLE) for functional rehabilitation of patients with stroke

Peidong He, Nikhil Tej Kantu, Boxin Xu, Chinmay P. Swami, Ghazala T. Saleem, and Jiyeon Kang

Int. J. Adv. Robot. Syst. 18 (2021)

2021
화면 캡처 2022-09-02 143312.png

A cable-actuated prosthetic emulator for transradial amputees

Souvik Poddar, David Cummiskey, and Jiyeon Kang

International Conference of the IEEE Engineering in Medicine & Biology Society (EMBC), 2021, 4529–4532

2020
화면 캡처 2022-09-03 064639.png

Promoting functional and independent sitting in children with cerebral palsy using the robotic trunk support trainer

Victor Santamaria, Moiz Khan, Tatiana Luna, Jiyeon Kang, Joseph Dutkowsky, Andrew M Gordon, and Sunil K. Agrawal

IEEE Trans. Neural Syst. Rehabil. Eng. 28 (2020) 2995–3004

2020
화면 캡처 2022-09-03 065047.png

Spherical parallel instrument for daily living emulation (SPINDLE) to restore motor function of stroke survivor

Peidong He, Boxin Xu, and Jiyeon Kang

IEEE Ras & Embs International Conference on Biomedical Robotics and Biomechatronics (BioRoB), 2020, 364–369

2020
화면 캡처 2022-09-03 065521.png

Challenges and opportunities for statistical monitoring of gait cycle acceleration observed from IMU data for fatigue detection

Saeb R. Lamooki, Jiyeon Kang, Lora A. Cavuoto, Fadel M. Megahed, and L. Allison Jones-Farmer

IEEE Ras & Embs International Conference on Biomedical Robotics and Biomechatronics (BioRoB), 2020, 593–598

2019
화면 캡처 2022-09-03 070409.png

A haptic object to quantify the effect of feedback modality on prosthetic grasping

Jiyeon Kang, Michael A. Gonzalez, R. Brent Gillespie, and Deanna H. Gates

IEEE Robot. Autom. Lett. 4 (2019) 1101–1108

2019
화면 캡처 2022-09-03 071511.png

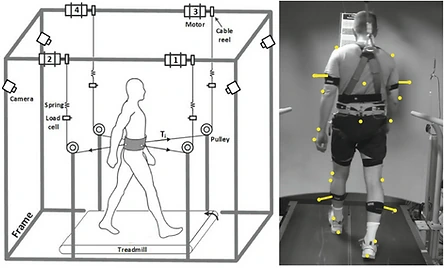
Simulating hemiparetic gait in healthy subjects using TPAD with a closed-loop controller

Jiyeon Kang, Keya Ghonasgi, Conor J. Walsh, and Sunil K. Agrawal

IEEE Trans. Neural Syst. Rehabil. Eng. 27 (2019) 974–983

2019
화면 캡처 2022-09-03 072602.png

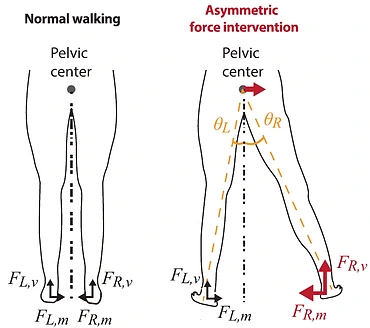
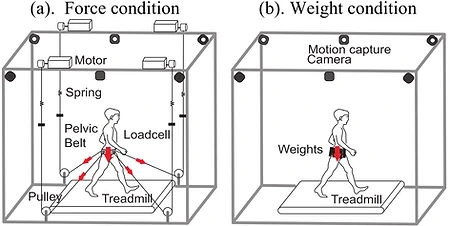
Walking with a weighted pelvic belt or with an equivalent pure downward force on the pelvis: are these different?

Keya Ghonasg, Jiyeon Kang, and Sunil K. Agrawal

IEEE Robot. Autom. Lett. 4 (2019) 309–314

2019
화면 캡처 2022-09-03 073154.png

Effects of repeated waist-pull perturbations on gait stability in subjects with cerebellar ataxia

Federica Aprigliano, Dario Martelli, Jiyeon Kang, Sheng-Han Kuo, Un J. Kang, Vito Monaco, Silvestro Micera, and Sunil K. Agrawal

J. Neuroeng. Rehabil. 16 (2019)

2018
화면 캡처 2022-09-03 080253.png

Chapter 9. Robot enhanced walkers for training of children with cerebral palsy: pilot studies. In Encyclopedia of rehabilitation robotics

Jiyeon Kang and Sunil K. Agrawal

The Encyclopedia of Medical Robotics (World Scientific, Singapore), 2018, 217–240 

2018
화면 캡처 2022-09-03 080741.png

A perturbation-based gait training with multidirectional waist-pulls generalizes to split-belt treadmill slips

Dario Martelli, Jiyeon Kang, and Sunil K. Agrawal

IEEE Ras & Embs International Conference on Biomedical Robotics and Biomechatronics (BioRoB), 2018, 7–12

2011− 2017
Capture+_2018-02-15-21-06-08.png

Robot-driven downward pelvic pull to improve crouch gait in children with cerebral palsy

Jiyeon Kang, Dario Martelli, Vineet Vashista, Isis Martinez-Hernandez, Heakyung Kim, and Sunil K. Agrawal

Science Robotics 2 (2017) eaan2634. 

2011− 2017
화면 캡처 2022-09-03 082452.png

On the adaptation of pelvic motion by applying 3-dimensional guidance forces using TPAD

Jiyeon Kang, Vineet Vashista, and Sunil K. Agrawal

IEEE Trans. Neural Syst. Rehabil. Eng. 25 (2017) 1558–1567

2011− 2017
화면 캡처 2022-09-03 091839.png

Adaptation of stability during perturbed walking in Parkinson's disease

Dario Martelli, Lan Luo, Jiyeon Kang, Un J. Kang, Stanley Fahn, and Sunil K. Agrawal

Sci. Rep. 7 (2017) 17875 

2011− 2017
화면 캡처 2022-09-03 092254.png

Enhancing seated stability using trunk support trainer (TruST)

Moiz Khan, Victor Santamaria, Jiyeon Kang, Brian Bradley, Joseph P. Dutkowsky, Andrew M. Gordon, and Sunil K. Agrawal

IEEE Robot. Autom. Lett. 2 (2017) 1609–1616

2011− 2017
화면 캡처 2022-09-03 092702.png

Design and preliminary evaluation of a multi-robotic system with pelvic and hip assistance for pediatric gait rehabilitation

Evelyn J. Park, Jiyeon Kang, Hao Su, Paul Stegall, Daniel L. Miranda, Wen-Hao Hsu, Mustafa Karabas, Nathan Phipps, Sunil K. Agrawal, Eugene C. Goldfield, and Conor J. Walsh

IEEE-RAS-EMBS International Conference on Rehabilitation Robotics (ICoRR), 2017, pp. 332–339

2011− 2017
화면 캡처 2022-09-03 093013.png

A single session of perturbation-based gait training with the A-TPAD improves dynamic stability in healthy young subjects

Dario Martelli, Jiyeon Kang, and Sunil K. Agrawal

IEEE-RAS-EMBS International Conference on Rehabilitation Robotics (ICoRR), 2017, pp. 479–484

2011− 2017
화면 캡처 2022-09-03 094014.png

Robot-enhanced mobility training of children with cerebral palsy: short-term and long-term pilot studies

Sunil K. Agrawal, Jiyeon Kang, Xi Chen, Mi Jung Kim, Youngmyung Lee, Sang Won Kong, Hyungpil Cho, and Gyung-Jin Park

IEEE Syst. J. 10 (2016) 1098–1106

2011− 2017
화면 캡처 2022-09-03 094831.png

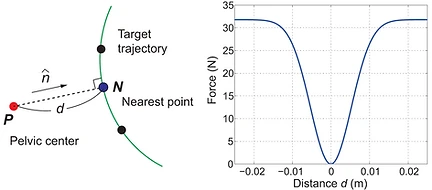
A novel assist-as-needed control method to guide pelvic trajectory for gait rehabilitation

Jiyeon Kang, Vineet Vashista, and Sunil K. Agrawal

IEEE International Conference on Rehabilitation Robotics (ICoRR), 2015, pp. 630–635

2011− 2017
화면 캡처 2022-09-03 095305.png

A chase-game to teach children on a robot to follow moving objects

Jiyeon Kang, Samuel Logan, James C. Galloway, and Sunil K. Agrawal

IEEE International Conference on Robotics and Automation (ICRA), 2014, pp. 234–239

2011− 2017
화면 캡처 2022-09-03 095814.png

Case studies of a robot enhanced walker for training of children with cerebral palsy

Sunil K. Agrawal, Jiyeon Kang, Xi Chen, Mi Jung Kim, Youngmyung Lee, Sang Won Kong, and Gyung-Jin Park

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2013, pp. 4243–4248

2011− 2017
화면 캡처 2022-09-03 100254.png

On the comfortableness of muscle power assistive robotic system

Jiyeon Kang, Keehoon Kim, Sin Jung Kim, and Sang Rok Oh

IEEE Ras & Embs International Conference on Biomedical Robotics and Biomechatronics (BioRoB), 2012, pp. 1759–1764

2011− 2017
화면 캡처 2022-09-03 100556.png

Minimum heat loss control of fluid-powered systems

Jiyeon Kang and Frank C. Park

International Conference on Control, Automation and Systems (ICCAS), 2011, pp. 1383–1387